
News
A high-tech factory specializing in flow meters
The company's instrument science and technology park covers an area of 100,000 square meters

The company's instrument science and technology park covers an area of 100,000 square meters
SCH16T-K01 | Murata 6-Axis IMU Inertial Measurement Unit (3-Axis Gyroscope + 3-Axis Accelerometer)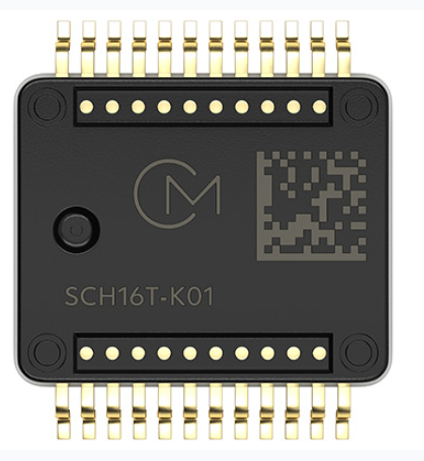
> One-sentence summary: 6DoF MEMS inertial sensor integrating 3-axis gyroscope and 3-axis accelerometer. It is a high-precision industrial / quasi-automotive grade IMU with SafeSPI secure digital interface for attitude, inclination and inertial navigation applications.
### Key Specifications
- Brand: Murata
- Structure: 3-axis gyroscope + 3-axis accelerometer (6 Degrees of Freedom, 6DoF IMU)
- Gyro Full-Scale Range: ±300 °/s (dps)
- Accelerometer Full-Scale Range: ±8g; auxiliary acceleration channel up to ±26g (shock resistance)
- Gyro Bias Stability: As low as 0.3~0.5 °/h (dph), excellent stability
- Noise Density: 0.3 mdps/√Hz
- Power Supply: VDD 3.0~3.6V; IO Voltage 1.7~3.6V
- Interface: SafeSPI v2.0 (secure SPI with data integrity check)
- Output Resolution: 16bit / 20bit optional
- Filter: Multiple low-pass filter options from 13Hz to 370Hz
- Operating Temperature: -40℃ ~ +110℃
- Package: SOIC-24, dimensions 12×14×3mm, SMD surface mount
- Certifications: AEC-Q100, RoHS
- Additional Features: Data Ready signal, timestamp, sync input, built-in hundreds of self-diagnostic functions
### Functions & Features
1. 3-axis angular velocity measurement (gyroscope): Detects rotation speed around X, Y, Z axes and calculates roll, pitch and yaw attitude angles.
2. 3-axis acceleration measurement: Detects acceleration along XYZ axes. It can measure static inclination (gravity) and capture vibration and shock events.
3. Internal cross-axis compensation: Factory calibrated to reduce cross-axis interference, eliminating complicated on-site calibration for customers.
4. SafeSPI secure SPI: Equipped with data checksum to prevent communication errors, suitable for high-reliability and safety-related equipment.
5. Built-in self-diagnosis: Real-time monitoring of internal sensor status with fault reporting to improve system reliability.
6. Timestamp + synchronization signal: Time alignment for multi-sensor fusion, facilitating integrated navigation algorithms.
>
> Core function: **Real-time acquisition of carrier attitude, inclination, angular velocity and acceleration, feeding data to MCU for attitude calculation, positioning and stabilization control.**
### Applications (for sales introduction to customers)
- Industrial inertial navigation, positioning and attitude measurement
- Attitude control for industrial robots, AGVs and robotic arms
- Flight controller for industrial drones (medium & small industrial models, not for high-dynamic applications. Select SCH16T-K10 (±2000 dps) for high-speed scenarios)
- Attitude and inclination monitoring for construction machinery and agricultural equipment
- Camera gimbal stabilization and antenna stabilization platforms
- Downhole exploration and MWD measurement while drilling (oil & gas industry)
- Attitude sensing for special vehicles
Key Takeaways
1. SCH16T-K01: Gyro range ±300 dps; sibling model SCH16T-K10: ±2000 dps, ±16g. Choose K10 for high-speed and high-shock environments.
2. AEC-Q100 qualified. Applicable for non-safety automotive domains and the primary part for industrial projects. **High precision and low bias drift are its biggest selling points.** It delivers far better stability than consumer-grade IMUs such as BMI270 at a higher price.
3. Supply voltage limited to 3.0~3.6V, commonly powered by 3.3V. Cannot be directly supplied with 5V.
4. SafeSPI interface. Compatible with regular SPI MCUs, but software development is required to enable the security check function.
5. Advantages: Good vibration resistance, low drift over temperature, suitable for long-term continuous attitude monitoring.
Welcome to consult, let's start to cooperate!
