
News
A high-tech factory specializing in flow meters
The company's instrument science and technology park covers an area of 100,000 square meters

The company's instrument science and technology park covers an area of 100,000 square meters
SCH1633-D01 (Murata 6-axis MEMS IMU, SCH1600 Series) | Automotive 6DoF Inertial Measurement Unit
SCH1633-D01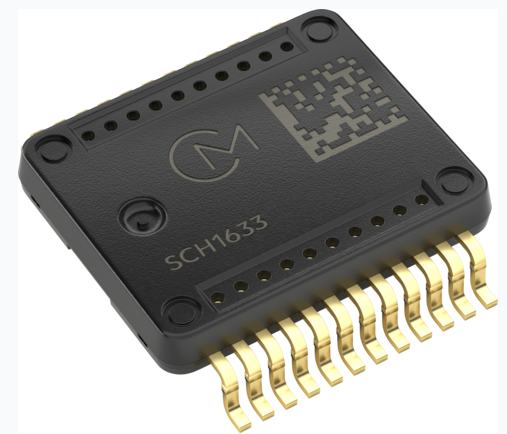
One-sentence definition**: Murata automotive-grade 6 Degrees of Freedom (6DoF) Inertial Measurement Unit. It integrates a 3-axis gyroscope and a 3-axis accelerometer in a single chip, compliant with AEC-Q100 Grade1 and ISO26262 ASIL-D, packaged in SOIC-24. It is an automotive central inertial navigation IMU.
Key Parameters
- Gyroscope range: ±300°/s; Primary acceleration channel ±8g, redundant acceleration channel up to ±26g
- Gyro bias stability: as low as 0.5°/h; Angular random walk: 0.03°/√Hz
- Operating temperature: -40℃ ~ +110℃
- Power supply: 3.0~3.6V, SPI interface (SafeSPI v2.0), with timestamp and SYNC sync input, over 200 internal self-test monitoring signals
- Factory-performed axis orthogonality calibration to reduce customers’ backend calibration cost
Functions & Features
1. 3-axis angular velocity measurement (gyroscope): Captures pitch/roll/yaw rotation rates of the vehicle to determine body attitude and steering motion.
2. 3-axis acceleration measurement (accelerometer): Captures vehicle linear acceleration and gravity tilt for inclination calculation.
3. Time synchronization + timestamp: Supports multi-sensor data fusion with GNSS, cameras, radars and LiDAR to eliminate time misalignment between sensors, a core capability for autonomous driving perception fusion.
4. Dead Reckoning (DR): Continuously estimates vehicle position via IMU when GPS/Beidou signals are lost (in tunnels, underground parking garages or under tall buildings).
5. Safety diagnostics: Extensive internal self-tests to meet automotive functional safety requirements for safety-related chassis systems.
6. Attitude output: Vehicle tilt angle and dynamic attitude for camera stabilization/correction and automatic headlamp leveling.
Application Scope (Automotive-focused)
- ADAS (Advanced Driver Assistance Systems): ACC, lane keeping, automatic emergency braking, etc.
- Autonomous Driving (AD): L2~L4 vehicle central inertial navigation, GNSS+IMU integrated positioning
- Vehicle chassis control: Electronic stability control, dynamic attitude monitoring
- Perception sensor calibration: Tilt compensation for onboard cameras and LiDAR
- Dynamic headlamp leveling: Complies with UNECE regulations for headlamp leveling
> Positioning: Central vehicle IMU. One component provides inertial data shared by multiple in-vehicle subsystems to lower BOM cost.
Welcome to consult, let's start to cooperate!
